
 village
Monitor & Hardware Setup
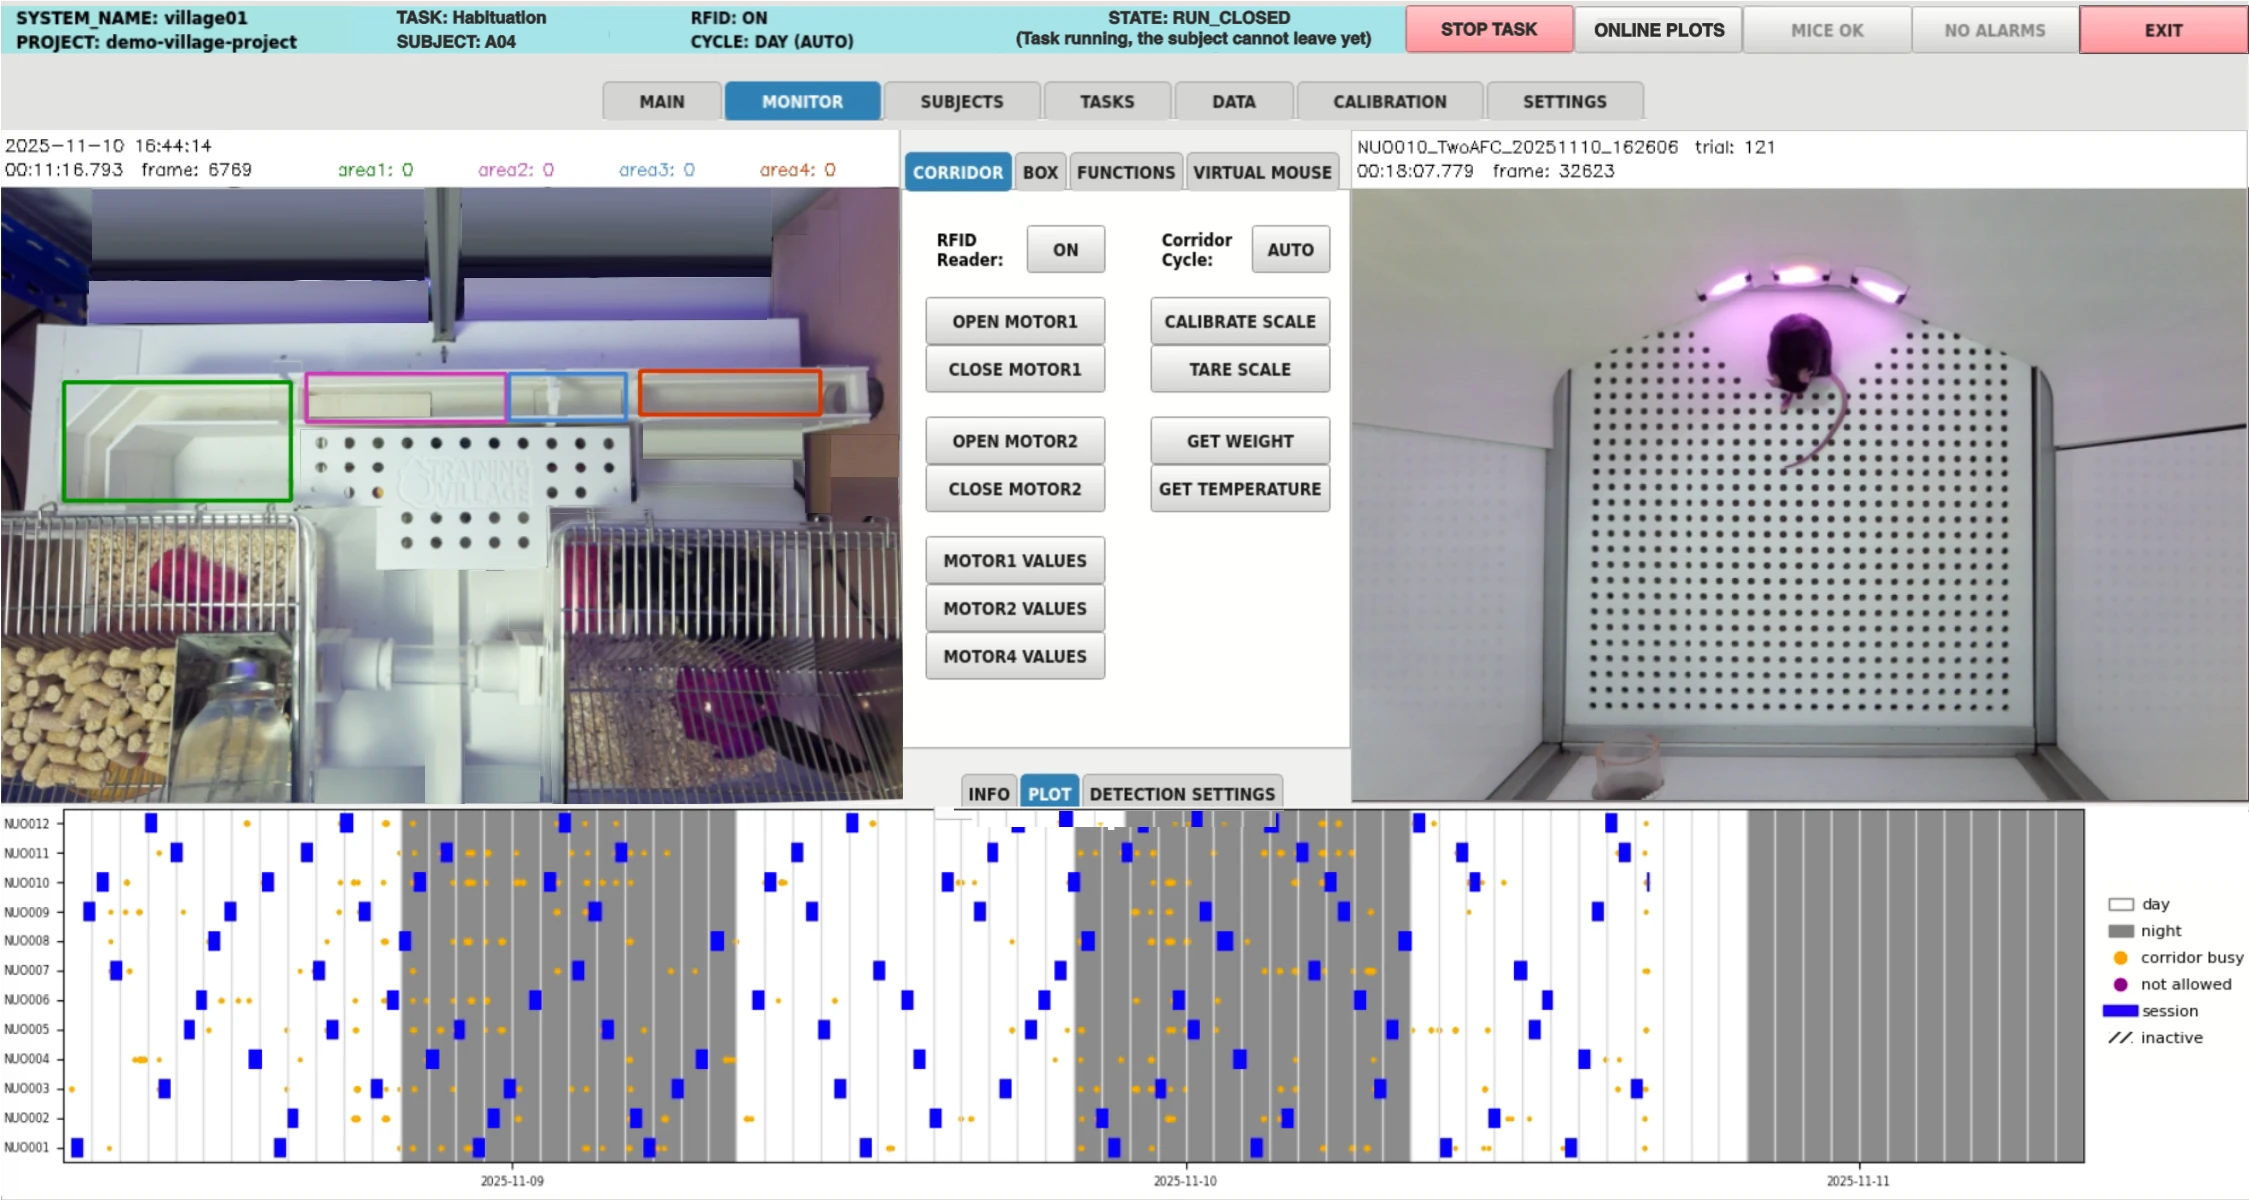
The MONITOR screen is used to track the system’s status, displaying real-time video feeds from both the corridor and the operant box, and to control and set up the hardware.
Control Tabs
Several control tabs are available at the center of the screen. Which ones are shown depends on your configuration:
CORRIDOR: only ifUSE_CORRIDORis ON (SETTINGS→CORRIDOR SETTINGS).BOX: only ifUSE_BOX_BOARDis ON (SETTINGS→BOX SETTINGS) or the behavioral controller is a Bpod.FUNCTIONS: always.VIRTUAL MOUSE: only if the behavioral controller is a Bpod, the box camera tracking is enabled (CAM_BOX_TRACKING_POSITION), orUSE_SCREENisTOUCHSCREEN.
CORRIDOR
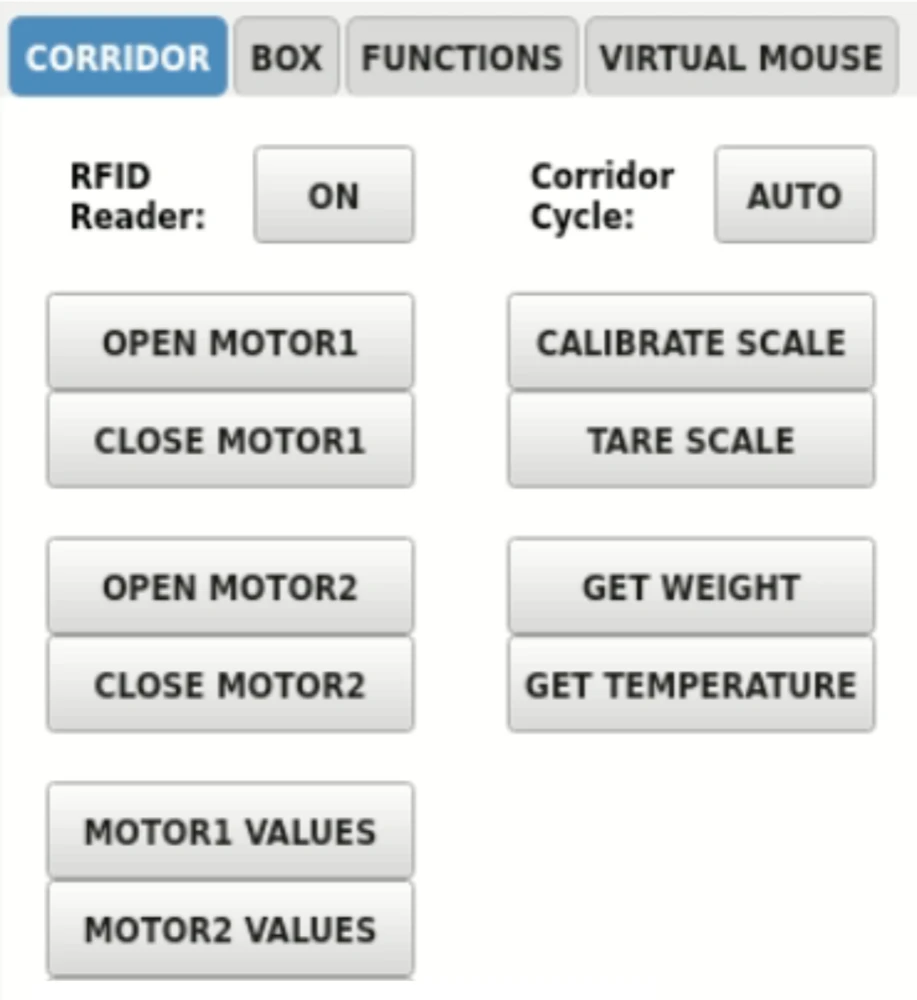
Provides manual control of the corridor hardware (RFID reader, doors, weighing scale and temperature sensor), and is where the corridor elements are set up.
RFID Reader: When it is toggled OFF, animal identification is disabled, and no subjects will be permitted to enter the operant box.Corridor Cycle: Lighting and camera exposure/thresholds are driven together by this control, which can be set toDAY,NIGHT, orAUTO.DAYturns the visible light ON and the IR light OFF, and applies the daytime camera exposure/threshold settings.NIGHTdoes the opposite: visible light OFF, IR light ON, and the nighttime camera exposure/threshold settings.AUTOswitches automatically betweenDAYandNIGHTaccording to the actual time of day; the daytime/nighttime schedule can be customized underSETTINGS→CORRIDOR SETTINGS.
Door motors
The OPEN MOTORx / CLOSE MOTORx buttons move each door with its saved values. To set those values, each installed motor has its own MOTORx VALUES button (MOTOR1/MOTOR2 are always shown; MOTOR3/MOTOR4 only appear if enabled in SETTINGS → CORRIDOR SETTINGS). Clicking it opens a dialog with the Open angle/Open time (ms) and Close angle/Close time (ms) fields, a Hold position checkbox, plus OPEN/CLOSE buttons to move the motor immediately and test the values before committing. The closing angle should allow the door to gently touch the top without pushing further.
Due to the symmetrical placement of the servomotors, the opening angle will be greater than the closing angle for one servo, while the opposite will apply to the other. Typically, the angular displacement between the open and closed positions is approximately 25° to 30°. The most straightforward way to calibrate the gates is by following these steps:
Temporarily detach the plastic gate from the servo horn.
Click CLOSE in the dialog, then manually place and secure the plastic gate in its physical “fully closed” position.
Modify the
Open anglefield by just a few degrees (either above or below the closed angle value). Click OPEN to verify that the servo rotates in the expected direction.Adjust the final
Open angleincrementally until the gate allows the animal to pass through easily when open.Once you are happy with the angles and times, click SAVE to persist them (or DISCARD to revert to the values the motor had before opening the dialog).
Hold position
Hold position sets what the motor does after it arrives, and it is saved per motor along with the angles and times:
Checked (the default): the servo stays powered and keeps its holding torque, so it actively holds its position and resists anything pushing on it.
Unchecked: the PWM signal is cut once the motor has arrived, so the servo goes quiet and cool. What happens next depends on the servo: some models keep holding their last position, while others go limp and can be pushed out of place.
For corridor doors, with the servos we use, keep it checked: otherwise the animal can push the door and force it open.
The checkbox takes effect immediately on OPEN/CLOSE, so you can test the behaviour before saving. It only sets the default: task code can override it for a single movement (see Motors).
A motor stops responding
If a motor stops responding to OPEN/CLOSE after being physically disconnected and
reconnected, restart Village rather than assuming it’s broken — see
Troubleshooting.
Scale
Use the CALIBRATE SCALE button with a known weight to calibrate the scale, TARE SCALE to zero it, and verify functionality by pressing GET WEIGHT.
Temperature sensor
Use the GET TEMPERATURE button to check temperature and humidity readings.
BOX
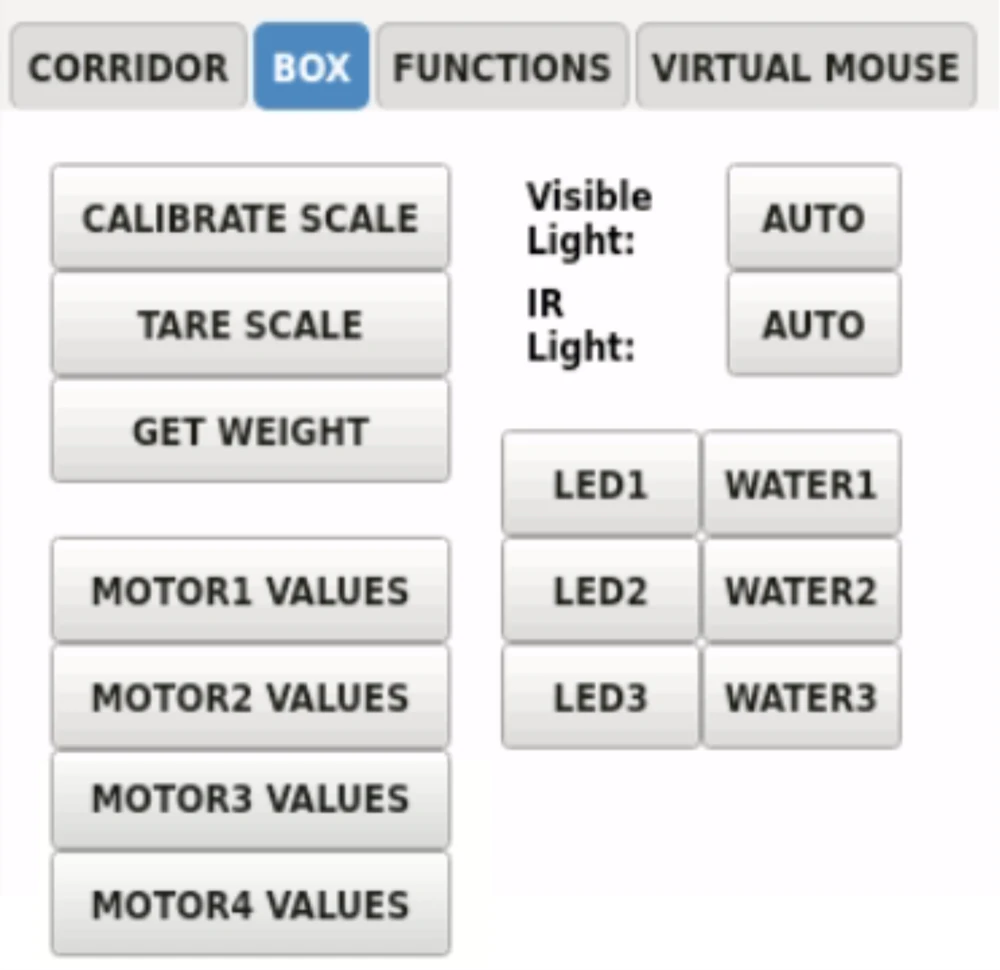
Provides dedicated controls for the lighting, scale and motor modules inside the operant box (as enabled in SETTINGS → BOX SETTINGS).
Visible Light/IR Light: Can be set toON,OFF, orAUTO. InAUTOmode, both visible and IR lights (if installed) are dynamically triggered: they switch ON automatically as soon as an animal enters the operant box and switch OFF once the subject leaves.The box must never be completely dark
The box camera is watched all the time, even between sessions, to check that no animal is left inside. If its image stays completely black for 10 seconds, the system treats the camera as failed and restarts it. Setting both lights to
AUTOis only safe if the box gets some light from another source (light coming in from outside, a photogate, a port LED…), enough for the image not to be fully black. If that is not the case, set theIR Light(or theVisible Light) toONinstead ofAUTO.Motors and scale: They work like the ones in the
CORRIDORtab. Each active motor (up toMOTOR1-MOTOR7, as enabled inSETTINGS→BOX SETTINGS) has its ownMOTORx VALUESbutton opening the same angle/time dialog. If a box scale is enabled (SCALE_BOX), the tab also has its ownCALIBRATE SCALE,TARE SCALE, andGET WEIGHTbuttons, calibrated independently from the corridor scale.LEDx/WATERx: Only if a Bpod is the behavioral controller. They turn on the LED of a behavior port, or deliver water (1-second valve opening) to it.
FUNCTIONS
Allows you to execute custom, user-defined Python functions in real time (e.g., displaying specific visual stimuli, playing auditory cues, etc.). Step-by-step instructions for writing and deploying these functions can be found in the Direct Functions section.
VIRTUAL MOUSE
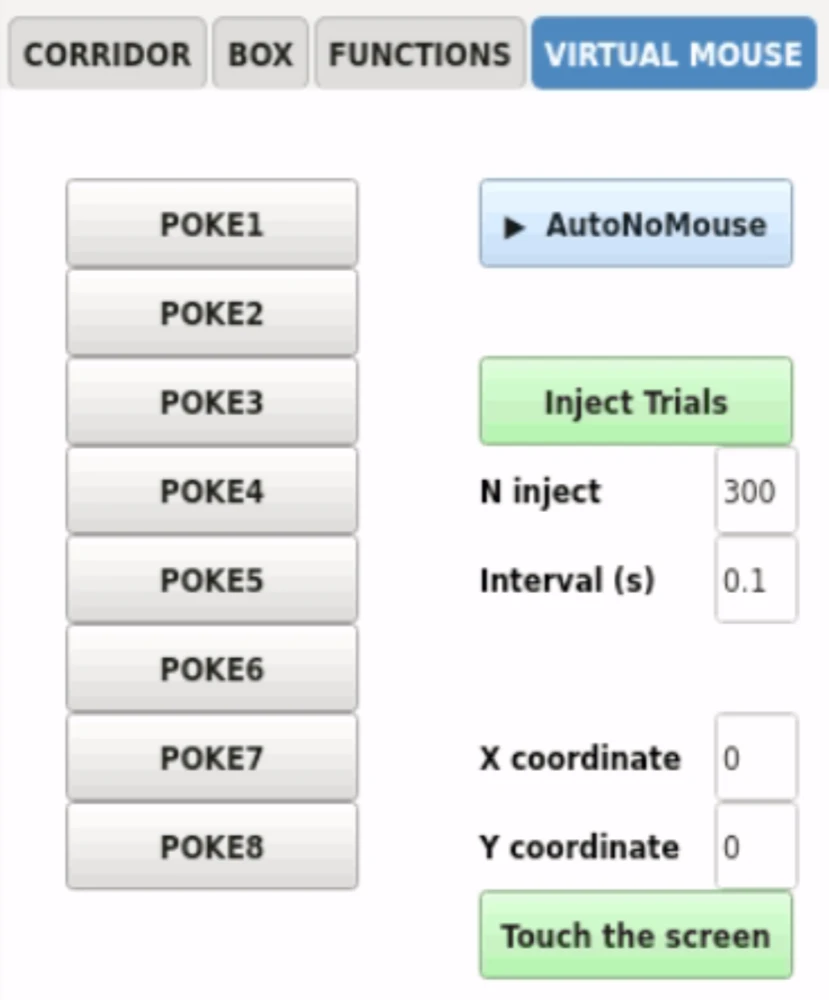
Enables real-time simulation of animal behavior through software triggers—an invaluable tool for debugging task logic and testing system responsiveness.
Bpod Integration (
POKE1-POKE8): Simulate a nose-poke in any behavior port with a single click.Touchscreen Integration: Simulate screen-touch events by sending precise coordinate inputs \((x, y)\) (
Touch the screen).AutoNoMouse: If the box camera tracking is enabled,
AutoNoMousestarts and stops a virtual animal that performs the running task by itself, andInject TrialsaddsN injectsimulated trials to the session data (one everyInterval (s)seconds), to fill a session quickly and test the plots or the training protocol. See Custom AutoNoMouse.
Bottom Tabs
A secondary group of tabs is located at the bottom of the screen to monitor system telemetry and history:
INFO: Displays a live stream of recent system events and operational logs. Double-clicking any logged event opens an expanded window with detailed diagnostic information.PLOT: Only withUSE_CORRIDORON. Shows a chart of the successful entries and the denied entry attempts of all subjects over the last three days.DETECTION SETTINGS: Provides fine-grained control over the computer vision and animal detection parameters for both the corridor and operant box tracking systems. A comprehensive breakdown of these parameters is available in the Animal Detection & Tracking.EXTRA: Only withCORRIDOR_AREA_EXTRAON (SETTINGS→ADVANCED SETTINGS). Configures the extra corridor area used to check that the passage between the two homecages is not blocked. See Homecage Camera Control.